FBT-300 Self-Propelled Robot

PRODUCT PARAMETERS

  • Model: FBT-300
  • Product Type: Self-Propelled Robot
  • Robot Configuration: 6-Axis Welding Robot
  • Mobile Platform: Self-Propelled Mobile Chassis
  • Working Radius: Approximately 2000 mm
  • Chassis Load Capacity: 300 kg
  • Welding Equipment: Welding Power Source and Water-Cooled Welding Torch
Description
FAQs
Request A Quote

Description

FBT-300 Self-Propelled Robot

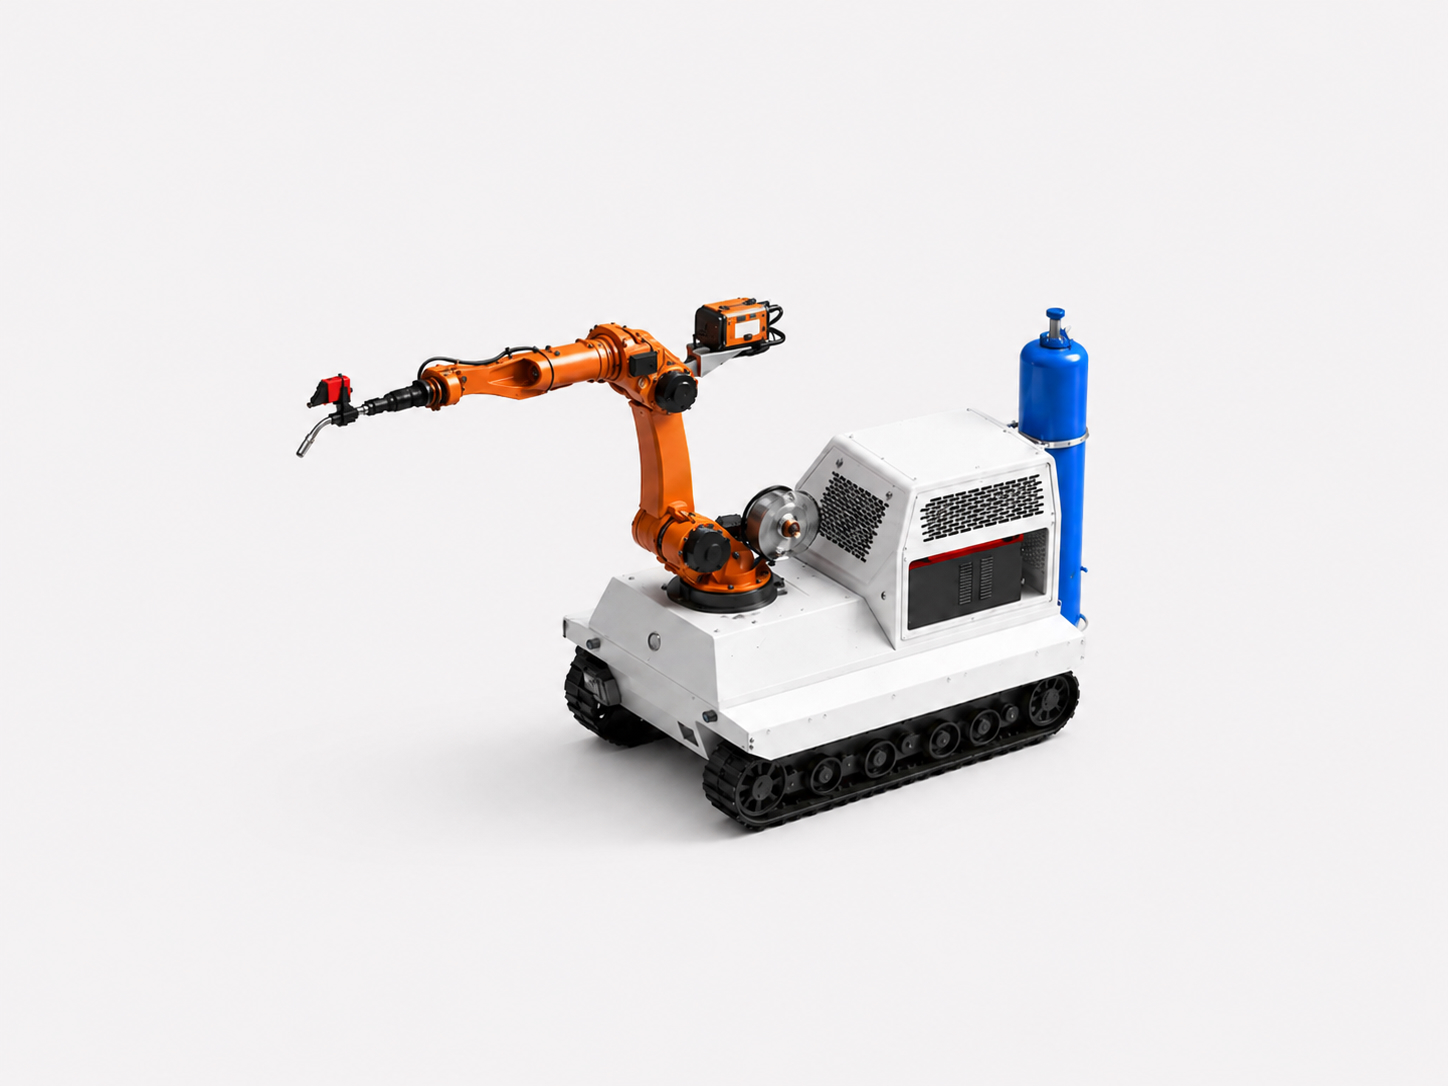
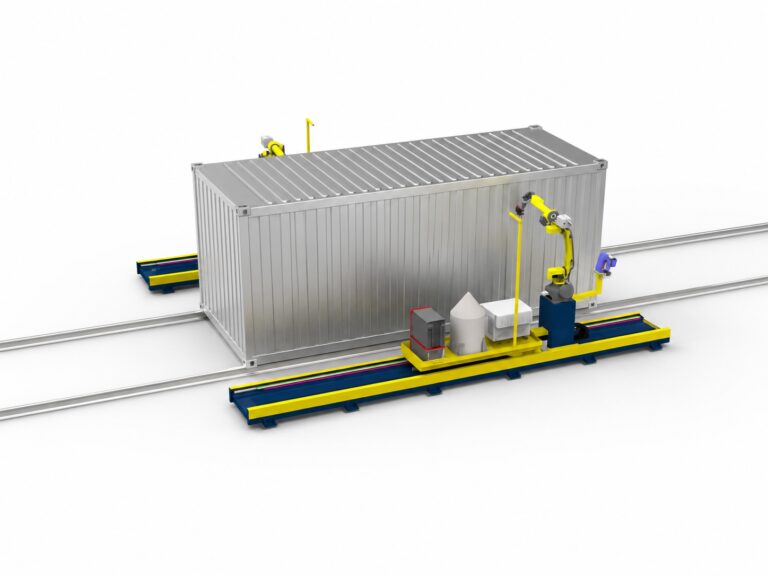
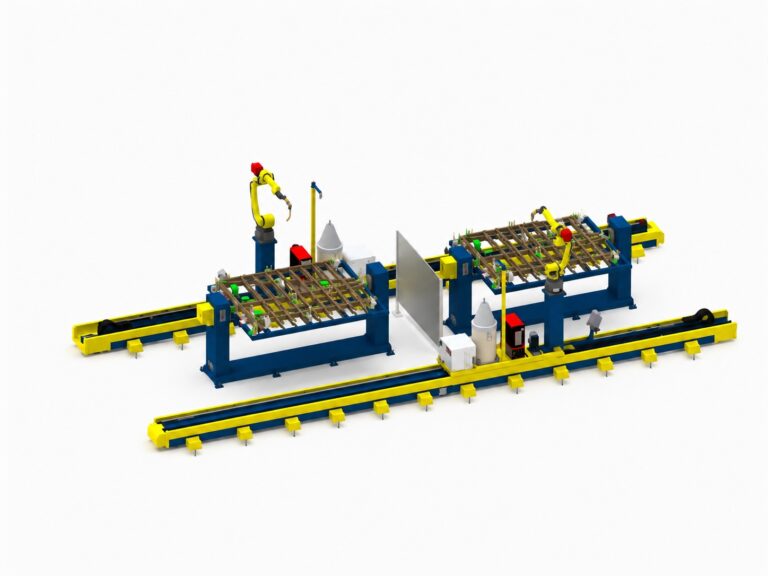
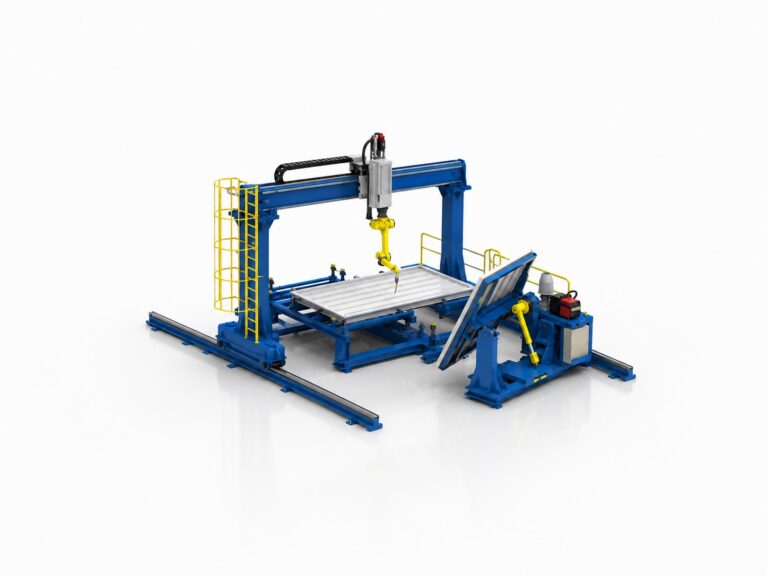
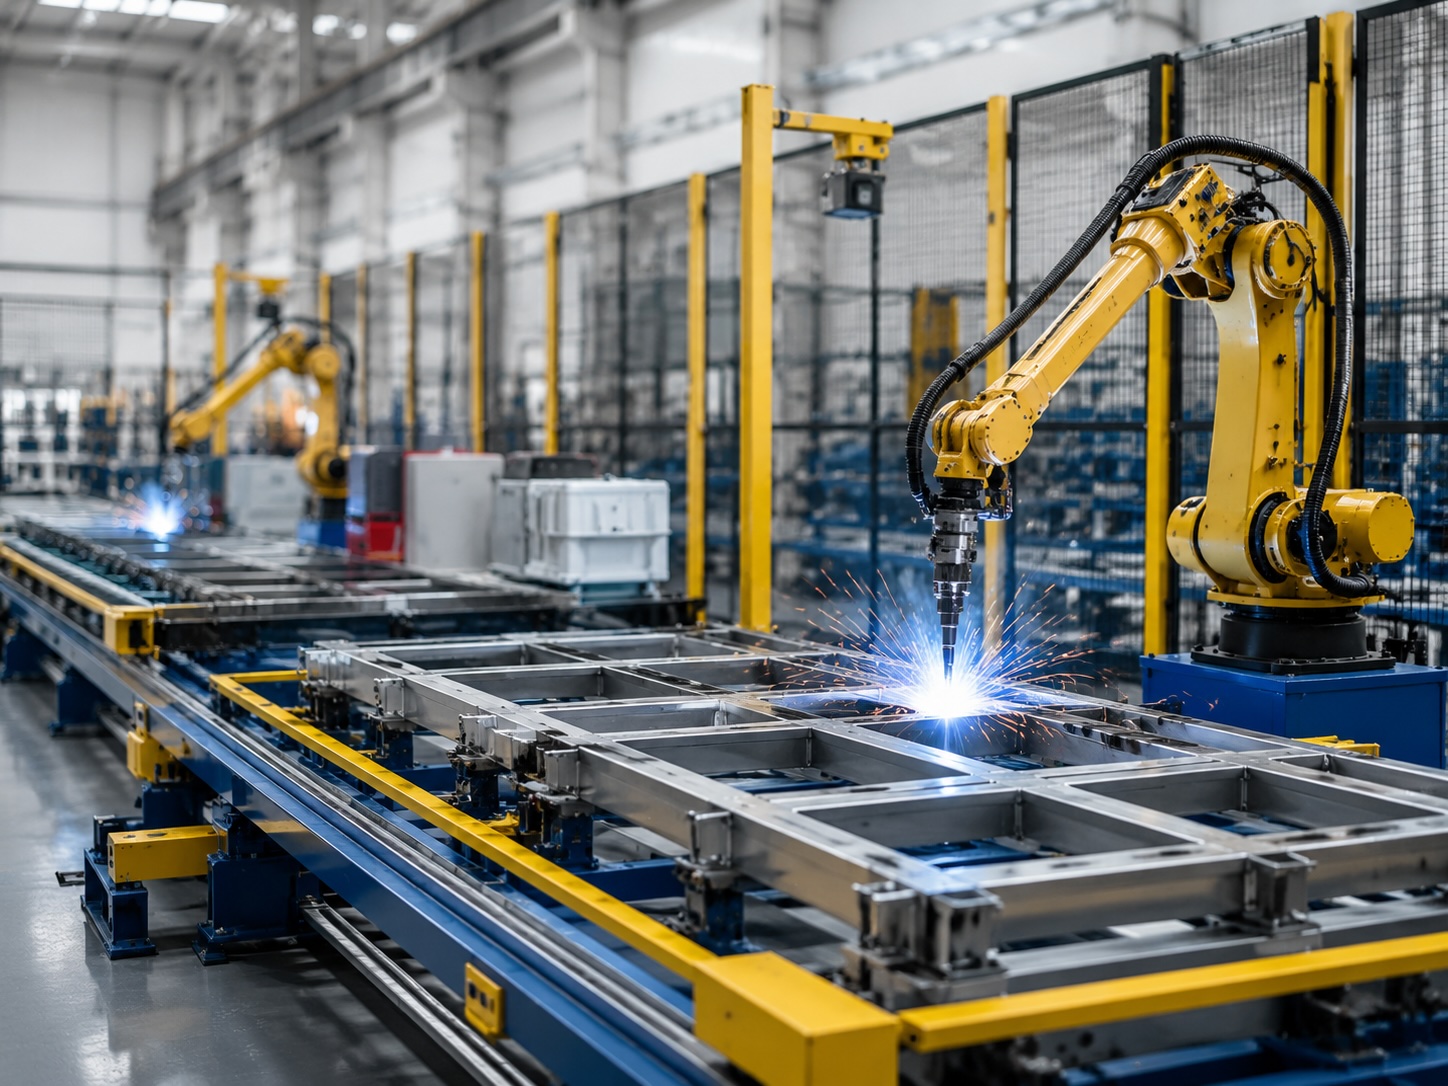
The FBT-300 self-propelled robot is a mobile robotic welding system designed for flexible welding operations. It combines a 6-axis welding robot with a self-propelled mobile chassis, allowing the equipment to move between different working positions according to actual production requirements.

The system is suitable for non-fixed workstations, temporary repair welding, local weld seam processing, and flexible on-site operations. Its visual scanning and control system supports weld scanning and welding path generation.

Applications

  • Temporary repair welding
  • Local weld seam processing
  • Non-fixed workstation welding
  • Flexible on-site welding operations
  • Supplementary welding for fixed workstations

Equipment Configuration

  • 6-axis welding robot
  • Self-propelled mobile chassis
  • Welding power source
  • Water-cooled welding torch
  • Visual scanning and control system

Product Features

  • Approximate working radius of 2000 mm
  • Mobile chassis with a load capacity of 300 kg
  • Supports visual scanning and welding path generation
  • Suitable for rapid deployment in production areas
  • Reduces the need for multiple fixed welding workstations
  • Supports flexible deployment between different working positions
  • Can be used as supplementary equipment for fixed robotic welding workstations

Main Technical Data

Product ModelFBT-300
Robot Type6-axis welding robot
Mobile PlatformSelf-propelled mobile chassis
Working RadiusApproximately 2000 mm
Chassis Load Capacity300 kg
Welding EquipmentWelding power source and water-cooled welding torch
Scanning SystemVisual scanning and control system
Path GenerationSupported

Configuration Description: The robotic workstation configuration should be selected according to the welding object, available working space, robot coverage range, and workpiece positioning method.

Note: The above technical information is based on the visible catalog information.

FAQs

Shandong Jisi Intelligent Equipment Co., Ltd. provides intelligent automation solutions including collaborative robot welding units, collaborative robot loading and unloading units, and crawler-type mobile welding robots.

Our products are designed for flexible manufacturing applications such as robotic welding, CNC machine tending, automatic material handling and welding automation.
Yes. Our automation solutions can be configured according to different workpieces, production processes, equipment layouts and application requirements.

Customization options may include robot configuration, welding processes, gripping solutions, workstation structure and system integration.

The suitable solution depends on factors such as workpiece size, material, production process, required operation, available installation space and equipment connection requirements.

Our team evaluates the actual working conditions and provides a suitable automation solution based on the customer’s manufacturing needs.

Collaborative robot systems are designed for flexible production environments. They can support human-machine cooperation, quick deployment, simple operation and adaptation to different production tasks.

They are suitable for applications requiring flexible automation, small-batch production and frequent product changes.

Yes. We provide technical support related to equipment setup, operation guidance and application solutions according to customer requirements.

Our goal is to help customers achieve stable operation and efficient automation production.

REQUEST A QUOTE

REQUEST A QUOTE